S.E.N.N.E.P. V2
2026 Rebuilding my robot, fully 3D printed Just started
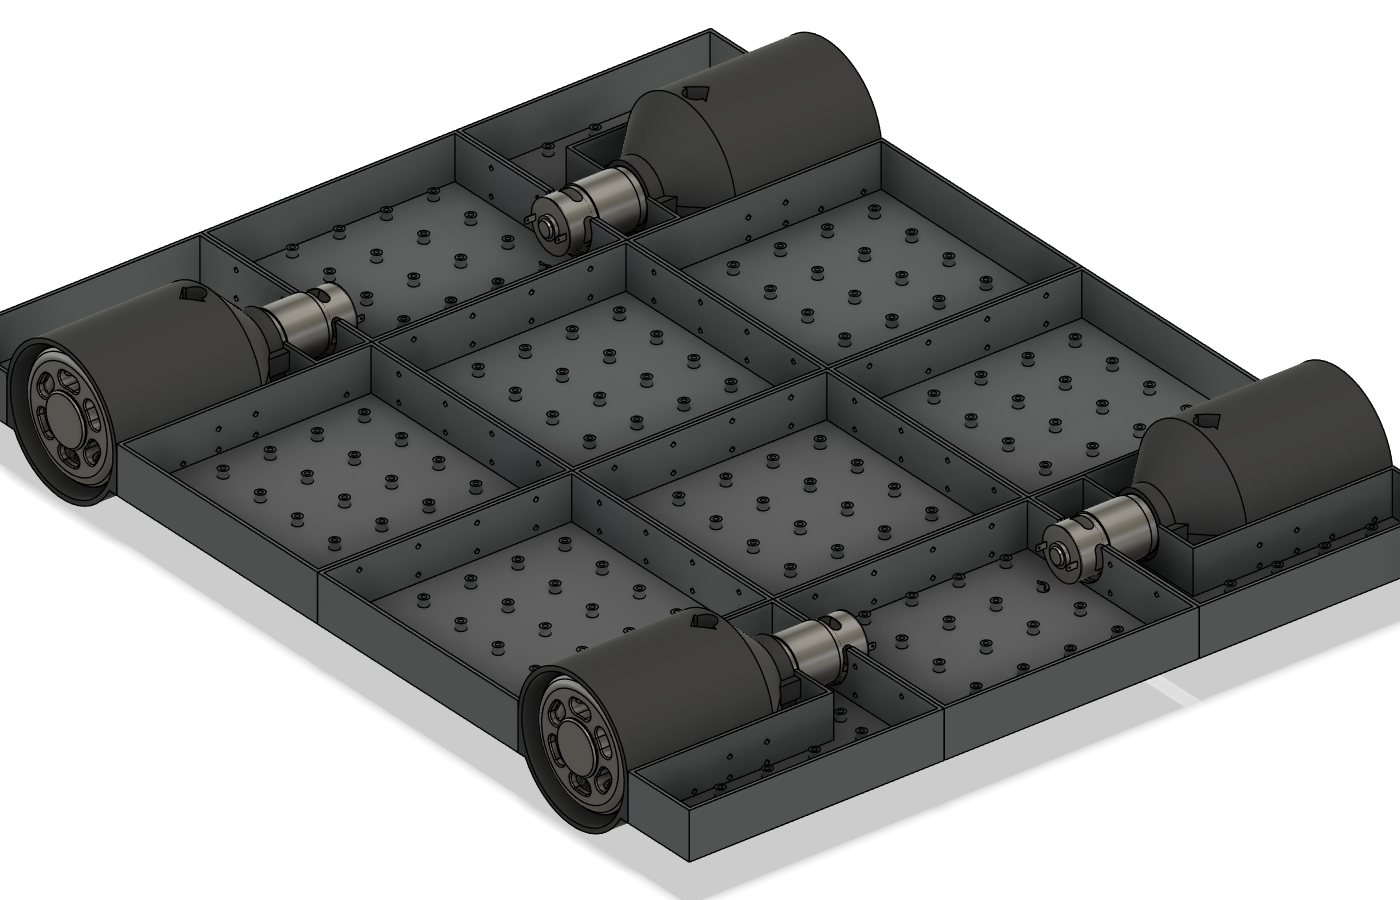
A rebuild of the robot from my HTX project, this time for fun and to learn. It drives on my own 3D printed mecanum wheels and should end up navigating on its own with a 360° LiDAR.
Why a V2
The idea has been around since the middle of 2025. Back then I got as far as a 3D design, which I ended up scrapping, and I bought components for about 6,000 kr., which have mostly been sitting in a box since. Now the plan is to actually get something driving, slowly but step by step.
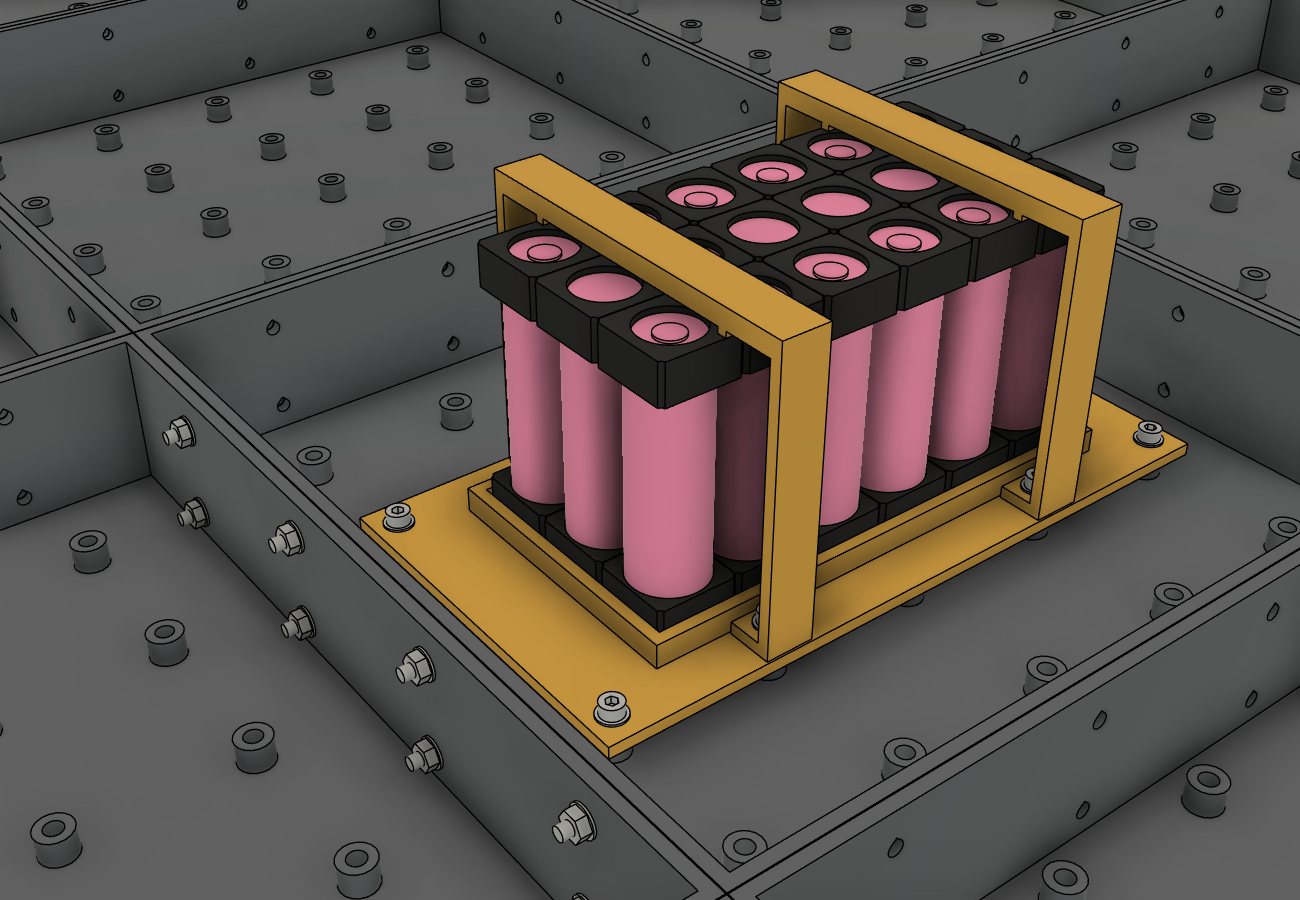
The first S.E.N.N.E.P. was mostly laser-cut acrylic, and an Arduino died along the way because of voltage spikes. V2 is a fresh start with the lessons from that: everything is 3D printed, the power side has a fuse, an emergency stop and protection against spikes, and the robot is designed to drive on its own instead of being a showpiece.
The plan
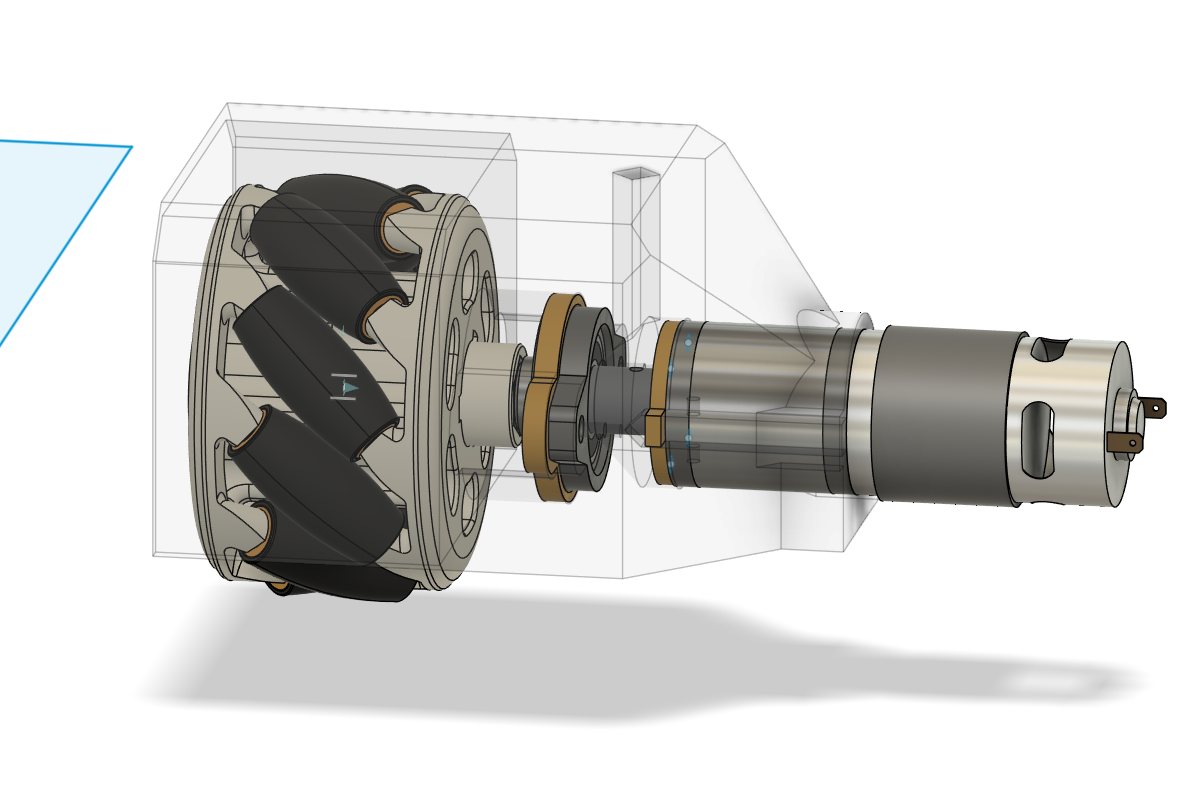
- Four of my own 110 mm mecanum wheels, sitting flush inside the body, so it can drive in every direction.
- A Raspberry Pi for the high-level part (LiDAR, camera, screen and most sensors) and an Arduino Nano for the motors and as a second layer of collision avoidance.
- A 360° LiDAR on a flat top, distance sensors around the bottom and edge detectors in the corners.
- Manual override with an RF joystick, and later a docking station.
So far
The wheels and the frame are generated by scripts in Fusion 360, so I can change a measurement and rebuild the part instead of redrawing it. I am printing test wheels to get the rollers right, and I have a small test app (Electron and Next.js) that reads and visualises the LiDAR data.